TL;DR

Get business pricing on tech for your team
- Business-only prices and quantity discounts
- Tax-exempt purchasing
- Multiple users, one account, clear invoices
Hugging Face has announced Grabette, an open handheld system that records human manipulation demonstrations without requiring a robot during collection. Its browser-based pipeline converts recordings into LeRobot datasets, but independent performance results, licensing details and adoption remain unclear.
Hugging Face has announced Grabette, an open, handheld system designed to record human manipulation demonstrations and convert them into robot-ready LeRobot datasets. The project aims to let researchers collect training data with a gripper, cameras and a human hand, without operating a robot during every demonstration.
Grabette combines two cameras, an inertial measurement unit and magnetic encoders in a handheld gripper. A wide-angle fisheye camera records the wrist-level view intended for a learned policy, while an OAK-D RGBD camera supplies color, depth and motion information for six-degree-of-freedom tracking. A Raspberry Pi records the sensor streams and gripper joint values using a shared clock.
During collection, a user presses a button, performs a task and presses the button again to save the episode locally. Through the browser-based Grabette dashboard, selected episodes can be uploaded to the Hugging Face Hub. The project says its Grabette-SLAM service uses RTAB-MAP to recover and check the device trajectory before converting the episode into LeRobot format.
The developers list an estimated bill of materials of about €490 for Grabette. A related motorized end effector called Gripette, estimated at about €120, is attached to a real or simulated robot arm when a trained policy is deployed. According to the announcement, hardware production files, Raspberry Pi capture software, the processing pipeline and an example training and evaluation stack are available as open-source components.
Lowering Robot Data Collection Costs
The release addresses a persistent limitation in robot learning: access to large, varied manipulation datasets. Conventional collection often requires a robot arm, a teleoperation system and repeated use of laboratory equipment. Grabette instead separates human demonstration recording from later execution by a robot, potentially allowing more tasks and environments to be captured with less equipment.
The use of standard LeRobot datasets may also make recordings usable across different training methods and robot platforms. Hugging Face says demonstrations store camera-local Cartesian poses and gripper state rather than assuming a particular arm. That could support shared data collection across institutions, although users still need a compatible Gripette end effector for the deployment setup described by the project.
Products Worth Considering
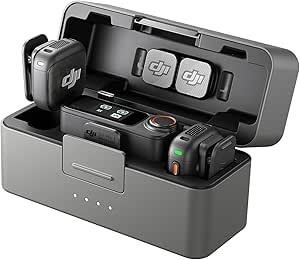
DJI Mic 3 Wireless Microphone System with 2 Transmitters, 1 Receiver, and Charging Case

DJI Osmo Pocket 3 Creator Combo 4K Vlogging Camera

DJI Mini 5 Pro Fly More Combo Camera Drone with RC 2 Controller
As an affiliate, we earn on qualifying purchases.
UMI Research Shapes Grabette
Grabette is directly inspired by Stanford researchers’ Universal Manipulation Interface, or UMI. UMI paired a handheld gripper and fisheye camera with simultaneous localization and mapping to record demonstrations outside fixed laboratory setups. Hugging Face credits that work with establishing the handheld collection approach behind its project.
The announcement also identifies commercial or closed-source collection devices from Agibot, Genrobot and Sunday Robotics. Grabette’s stated distinction is its combination of buildable hardware, open software, browser-based processing and Hugging Face Hub distribution. The developers say they have worked on the system for several months and now regard it as usable enough for public release, rather than presenting it as a finished production platform.
“The bottleneck isn’t the model. It’s the data.”
— Hugging Face’s Grabette project team
Performance Evidence Is Still Limited
The supplied announcement does not provide independent testing or peer-reviewed results comparing Grabette with robot teleoperation, UMI or commercial capture devices. It is also unclear how reliably the system tracks fast movements, reflective objects, occlusions or scenes where visual SLAM loses position. The pipeline checks for jumps and tracking loss, but no acceptance rates or failure statistics were supplied.
The article does not specify the number or diversity of demonstrations collected so far, the size of any shared dataset, or whether policies trained on contributed data transfer consistently between robot arms. Specific software and hardware license terms, contributor governance and quality-control rules were also absent from the supplied material. The listed €490 and €120 component costs are estimates and may vary by location and availability.
Community Collection Becomes the Test
The next measure of the project will be whether researchers and builders can assemble the hardware, reproduce the processing workflow and contribute useful demonstrations. Hugging Face is inviting users to record their own tasks and publish datasets through the Hub and LeRobot ecosystem.
Future evidence will need to show dataset growth, recording reliability and policy performance on real and simulated arms. Updates to documentation, licensing, benchmark results and validation procedures would clarify whether Grabette can support the large collaborative dataset described by its developers.
Key Questions
What is Grabette?
Grabette is a handheld gripper that records camera, depth, motion and gripper-state data while a person demonstrates a manipulation task. Its processing pipeline converts the recording into a LeRobot dataset for robot-policy training.
Does Grabette require a robot during recording?
No robot is required for the demonstration-recording stage. A person moves Grabette by hand, but a robot arm and compatible Gripette end effector are needed for the deployment workflow described in the announcement.
How much does the system cost?
Hugging Face estimates a bill of materials of about €490 for Grabette and about €120 for Gripette. Those figures exclude possible shipping, fabrication, robot-arm and computing costs.
How are recordings processed?
Selected episodes are uploaded through a browser dashboard. The hosted pipeline uses RTAB-MAP for trajectory reconstruction and checks, converts accepted recordings into LeRobot format and publishes the resulting dataset to the user’s Hugging Face space.
Has Grabette’s performance been independently verified?
The supplied source does not cite independent benchmarks or peer-reviewed evaluation of Grabette. Claims about usability, cost and data quality currently come from the project’s own announcement.
Source: Hugging Face